The development of new sensor hard- and software components within the ViTOS-Testbed is the first step in the life cycle of optical sensors. Subsequently, the individual hardware components are manufactured, tested and integrated into the surrounding system. This is precisely where ViTOS-II comes into play.
In ViTOS-II, processes are researched and the necessary components are developed, which provide a seamless transition from the simulated prototype to the real system in a real environment. Following the ideas of virtual commissioning and gradual substitution from the industrial manufacturing sector, ViTOS-II enables the successive replacement of individual simulated elements by corresponding emulated or real components and thus a continuous transition from the simulated to the real system.
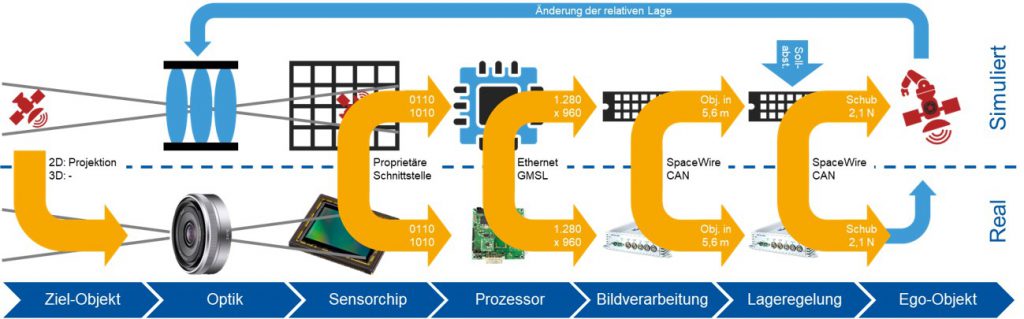
For this purpose, components of Experimental Digital Twins (EDT) of real sensor data processing systems are developed whose structures allow a 1-to-1 representation of the closed loop. Through the use of natural – as used and often standardized in reality – interfaces, switches between simulation and reality are provided at any point of the data processing chain realizing the novel approach of Hybrid Twins.
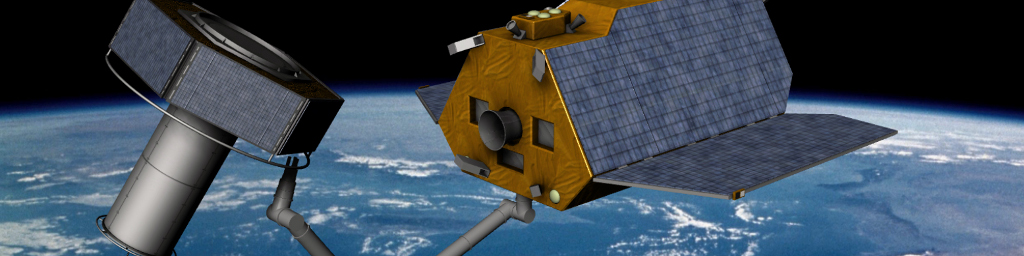
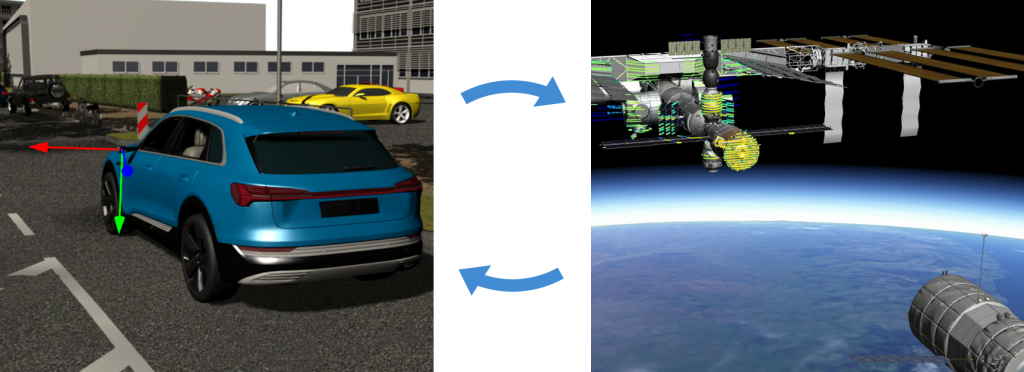
Here, the ViTOS-Testbed and the associated processes shall be seamlessly integrated in the development processes of the participating industrial players from the Space and Automotive sectors. Afterwards, the validation of the research results shall be validated under using the pre-defined reference scenarios “LiDAR-Based Rendezvous & Docking” and “Intelligent Camera Monitor System”. With the objective of developing generic models and processes that provide a physically-based simulation of the sensor types LiDAR and camera as well as a bidirectional technology transfer between Space and Automotive. ViTOS-II picks up on this complexity and researches solutions to overcome it.
Weitere Projekte

Living Lab for Precision and Robotisation in Fruit Growing Fruit growers across the Meuse-Rhine region face growing...

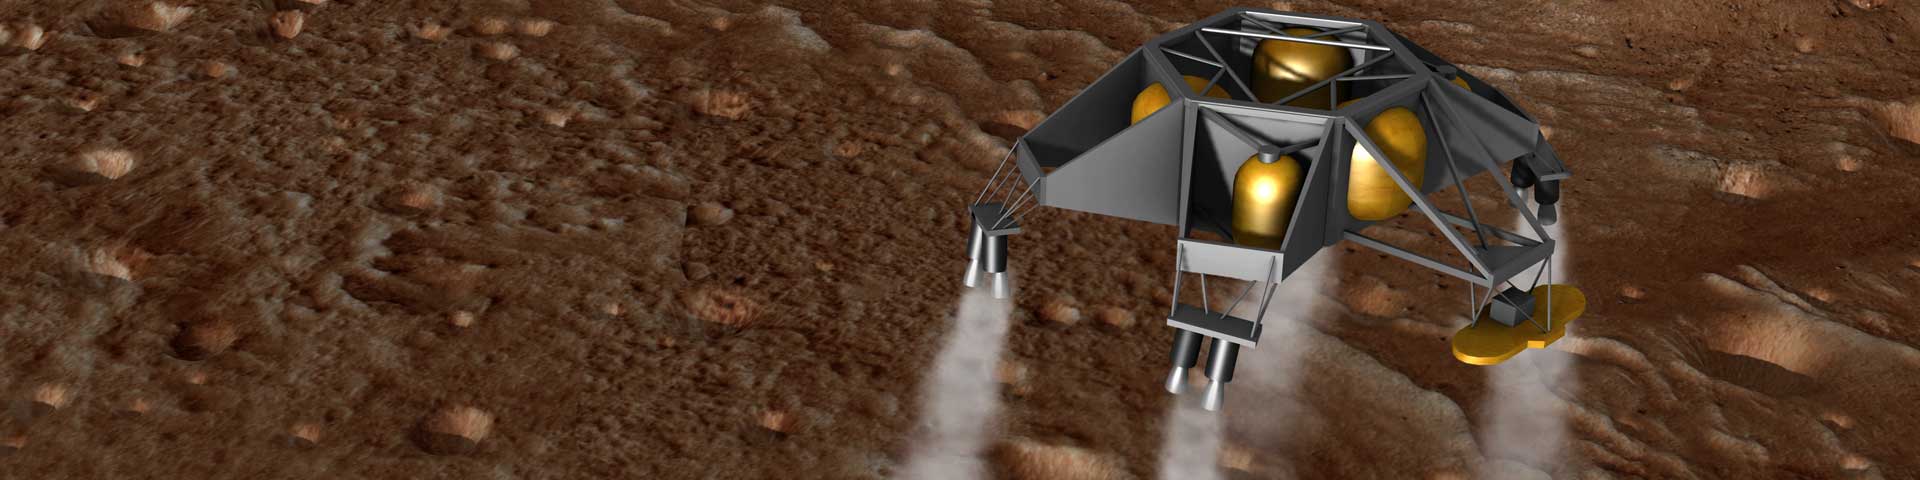
The “Mars Sample Return (MSR)” mission planned by NASA and ESA is probably one of...
In AsTeDiF, an assistance system is being developed to support the machine operator in operational...
The Twins4Space project develops a decentralized software platform for orchestrating Digital Twins and Services, enabling...
A tufting machine embroiders a backing material through the interaction of needle, looper and phase....
A picture is worth a thousand words, a video is worth a thousand pictures –...
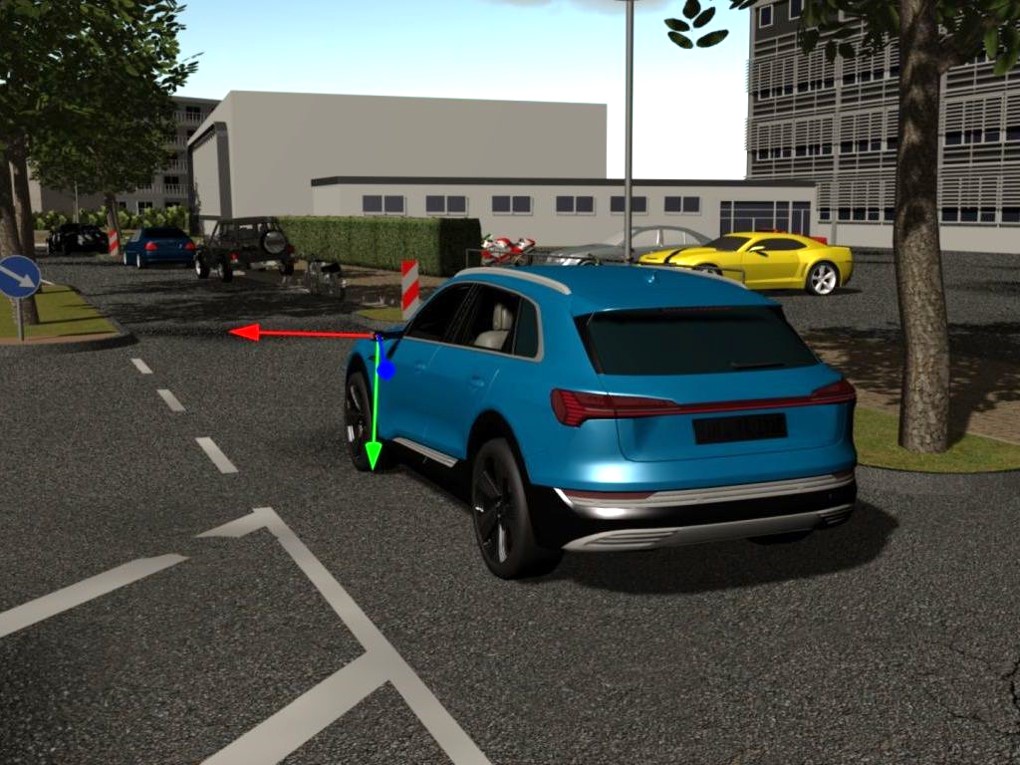
Die Entwicklung neuer Sensorhard- und -software im ViTOS-Testbed ist der erste Schritt im Lebenszyklus optischer...
The objective of the DeLas project is the significant reduction of process development and production...
"ReconCell" develops a new type of robot workcell, its required process infrastructures and the economic...
The forest information and management system "Virtual Forest" finally takes the long era of literally...
The objective of the DeLas project is the significant reduction of process development and production...
The “IntellAct” project is developing a system that can learn through observing assembly tasks demonstrated...
The basis for the techniques, components and processes that are to be developed within the...
Optical sensors are indispensable in almost all space flight applications. Within the framework of robotic...
SELOK investigates how landmarks from a mobile robot dependent on the robot position among others...
The ProDemo project series deals with robot programming by demonstration and with 3D modelling by...
The Scalable Automation for Emerging Lab Production project (SCALAB) has as its objective the systematization...
Within the framework of the Virtual Crater project, a test environment was developed which makes...
Today’s satellites are mostly monolithic systems without the option of maintenance, upkeep or reconfiguration.
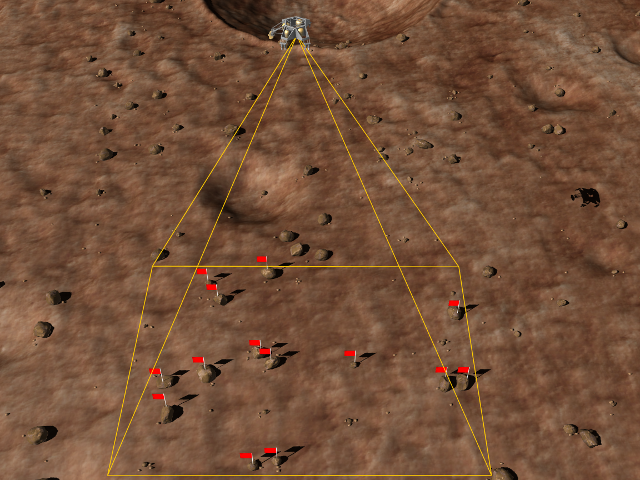
An important issue that arises in the exploration of strange planets by robots that to...
Katastrophen wie das Reaktorunglück von Fukushima zeigen deutlich, dass die Fähigkeiten aktueller Robotersysteme zur Katastrophenbewältigung...